Sofia Thunberg is a postdoctoral researcher in human-computer interaction at Uppsala University. Sofia is part of the Human Technology and Organisation (HTO) research group.
Human-drone interaction is an emerging field investigating ways to extend the conventionally passive role of drones with autonomous, socially interactive functionalities. Drones offer unique opportunities for applications, such as exercise support, due to their mobility and flexibility. While previous research has studied drones for, e.g., pacing, gait analysis, and accessibility in running contexts, we propose that an equally crucial part of such applications is the socially interactive role of the drone.
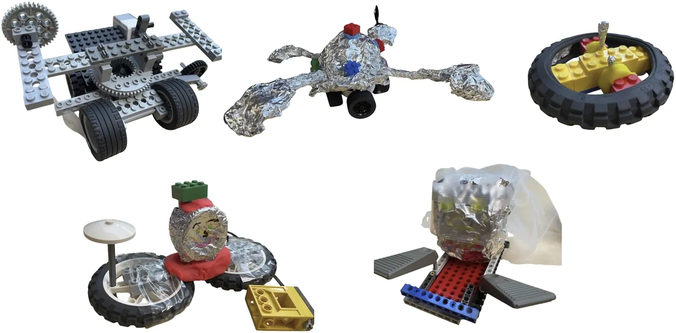
Our paper “Investigating social drones for recreational running through co-design” was recently published in Frontiers in Robotics and AI. In this paper, Stine Schmieg Johansen, Martin Bergström, Mohammad Obaid, and I, present a study in two phases. In the first phase, we conducted a preliminary study that informed the design of a co-design workshop through eight semi-structured interviews exploring drone support for runners. In the second phase, we designed and conducted a co-design workshop with five experienced recreational runners to reflect on the practical and ethical challenges of using drones and to envision ways in which drones could support and interact with runners in future scenarios. The results present five low-fidelity social drone prototypes (seen above), including participants’ reflections tied to each prototype. Furthermore, we present analytical themes that demonstrate the necessity of extending and re-framing approaches to designing social drones.
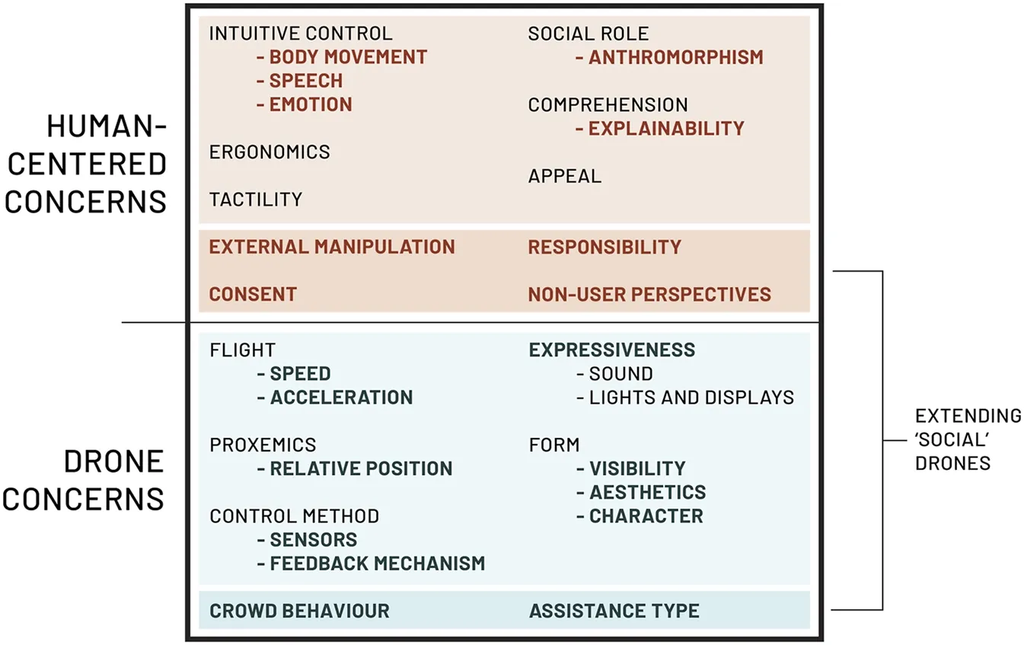
The results expanded the Design Space for Social Drones framework, previously developed by Bayatas et al. (2019). Bold = Extensions derived from the thematic analysis. Bottom of the two sections are non-user concerns.
Citation: Thunberg S, Schmieg Johansen S, Bergström M and Obaid M (2026) Investigating social drones for recreational running through co-design. Front. Robot. AI 13:1897014. doi: 10.3389/frobt.2026.1897014
Vi är glada att välkomna Alexandra Sandell som forskningsintern hos HTO nu under hösten. Alexandra har en bakgrund inom människa-datorinteraktion och psykologi. I människa-datorninteraktionsprogrammet på Institutionen för informatik och media finns det möjlighet till en tio veckors praktik i en forskargrupp och vi är väldigt glada att Alexandra ville testa på att vara hos oss.
Alexandras projekt handlar om cyberaggressioner (t.ex. trakasserier, hot och doxxning) mot vårdpersonal via sociala medier och i andra digitala forum. Hon kommer undersöka detta via webbskrapning och NLP-metoder.
Beyond ‘Green Growth’: Why HRI Needs a Post-Growth Perspective
The field of Human-Robot Interaction (HRI) is at a crossroad. As we design more sophisticated robots for healthcare, education, and the home, we are forced to reckon with that our technological progress is deeply intertwined with an economic model that demands perpetual growth—often at a steep cost to our planet.
In our new paper, ‘Post-growth Perspectives in HRI’, recently presented at HRI ’26 in Edinburgh, my co-authors (Mafalda Gamboa, Ilaria Torre, and Birgit Penzenstadler) and I argue that it’s time to look beyond the ‘green growth’ narrative.
The Problem with ‘Business as Usual’
Climate research has pointed out that economic growth is the root cause of environmental devastation, and the most prevalent ‘rescue narrative’ is that productivity growth will recover through new technological breakthroughs. But, this narrative rarely account for the limits to the planetary resources.
Almost all improvements in user interactions increase energy and resource consumption. The carbon emissions from training Large-Language Models is one example, and emissions from sensors and components are also mainly caused by energy consumption. All parts, both software and hardware, of the robots the HRI community are building and buying are, therefore, (somewhat) harmful to our planet.
In parallel, we are seeing a growing graveyard of social robots, where many of the robot platforms that the field has relied on are going bankrupt due to not being able to expand and grow beyond academic buyers. We argue that HRI cannot solely rely on the unstable market of social robots and the market mechanisms that the field is deeply tied to, such as software-as-a-service and robot-as-a-service, which by many large companies is often driven by robotwashing. To tackle this, we point to self-built and low-scale robots, even though they are not exempt from the material dependencies of the broader growth paradigm.
Introducing Post-growth for HRI
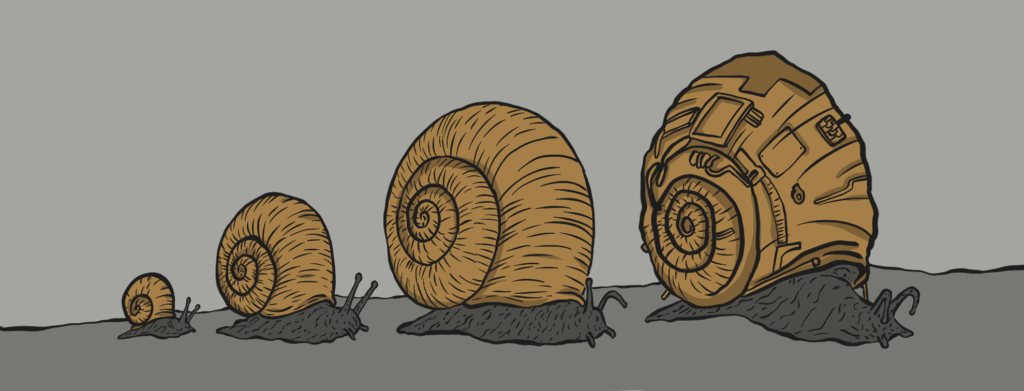
Our paper introduces a post-growth perspective to HRI, by inviting the community to shift the focus from quantitative growth to qualitative development. We reuse the metaphor of the snail (broadly used by the degrowth and slow movements) and add a new ring on the snail’s shell—a layer of automation, artificial intelligence, and robotics, built upon already complex structures. While intended to enhance efficiency and productivity, this continual layering risks creating fragility, dependence, and ecological or social imbalance. The metaphor thus warns of the limits of accumulation and invites reflection on how to achieve balance for HRI.
To help researchers and practitioners navigate this shift, we propose three actionable steps:
Ask ‘Question Zero’: Inspired by the question zero for the use of AI: ‘why AI?’, we, in our version, ask ‘why robots?’. Asking this forces criticality and more detailed motivation for why a robot is needed and for whom. Question zero can also inform research that examines real-world applications in need of critique. Beyond refusal, the question seeks to find cases in need of assessment and possible exnovation.
The Post-growth Manifesto: We suggest a manifesto (see below), that comes with a glossary. Here, we list a number of conventional understandings of robots in HRI based on our reading of the field, in opposition to a list of important notions within post-growth for HRI. It can be a tool to locate, discuss, and negotiate ongoing research, and in doing so, we encourage leaning into the B side to support a post-growth orientation.
Sustainability Statements: Just as ethical and positionality statements have become standard, we propose a template for sustainability statements. These encourage researchers to reflect on the environmental, social, and economic impacts of their work.
Why This Matters
As HRI researchers, we have the power to define what the ‘future’ looks like. By embracing post-growth, we aren’t ‘anti-technology’. Instead, we are advocating for a future where robotics serves humanity and the biosphere without being tied to the destructive cycle of endless extraction.
We hope this paper serves as a call to reflexivity and criticality. It’s time to consider not just how we build and deploy robots, but for whom and at what cost.
Citation:Sofia Thunberg, Mafalda Gamboa, Ilaria Torre, and Birgit Penzenstadler. 2026. Post-growth Perspectives in HRI. In Proceedings of the 21st ACM/IEEE International Conference on Human-Robot Interaction (HRI ’26). Association for Computing Machinery, New York, NY, USA, 1388–1398.
In our research group, we study the relationships and dynamics of Human, Technology, and Organisation (HTO) to create knowledge that supports sustainable development and utilization of ICT.